Ashwin Gupta
Agile and Intelligent Robotics Lab, Johns Hopkins University
About Me
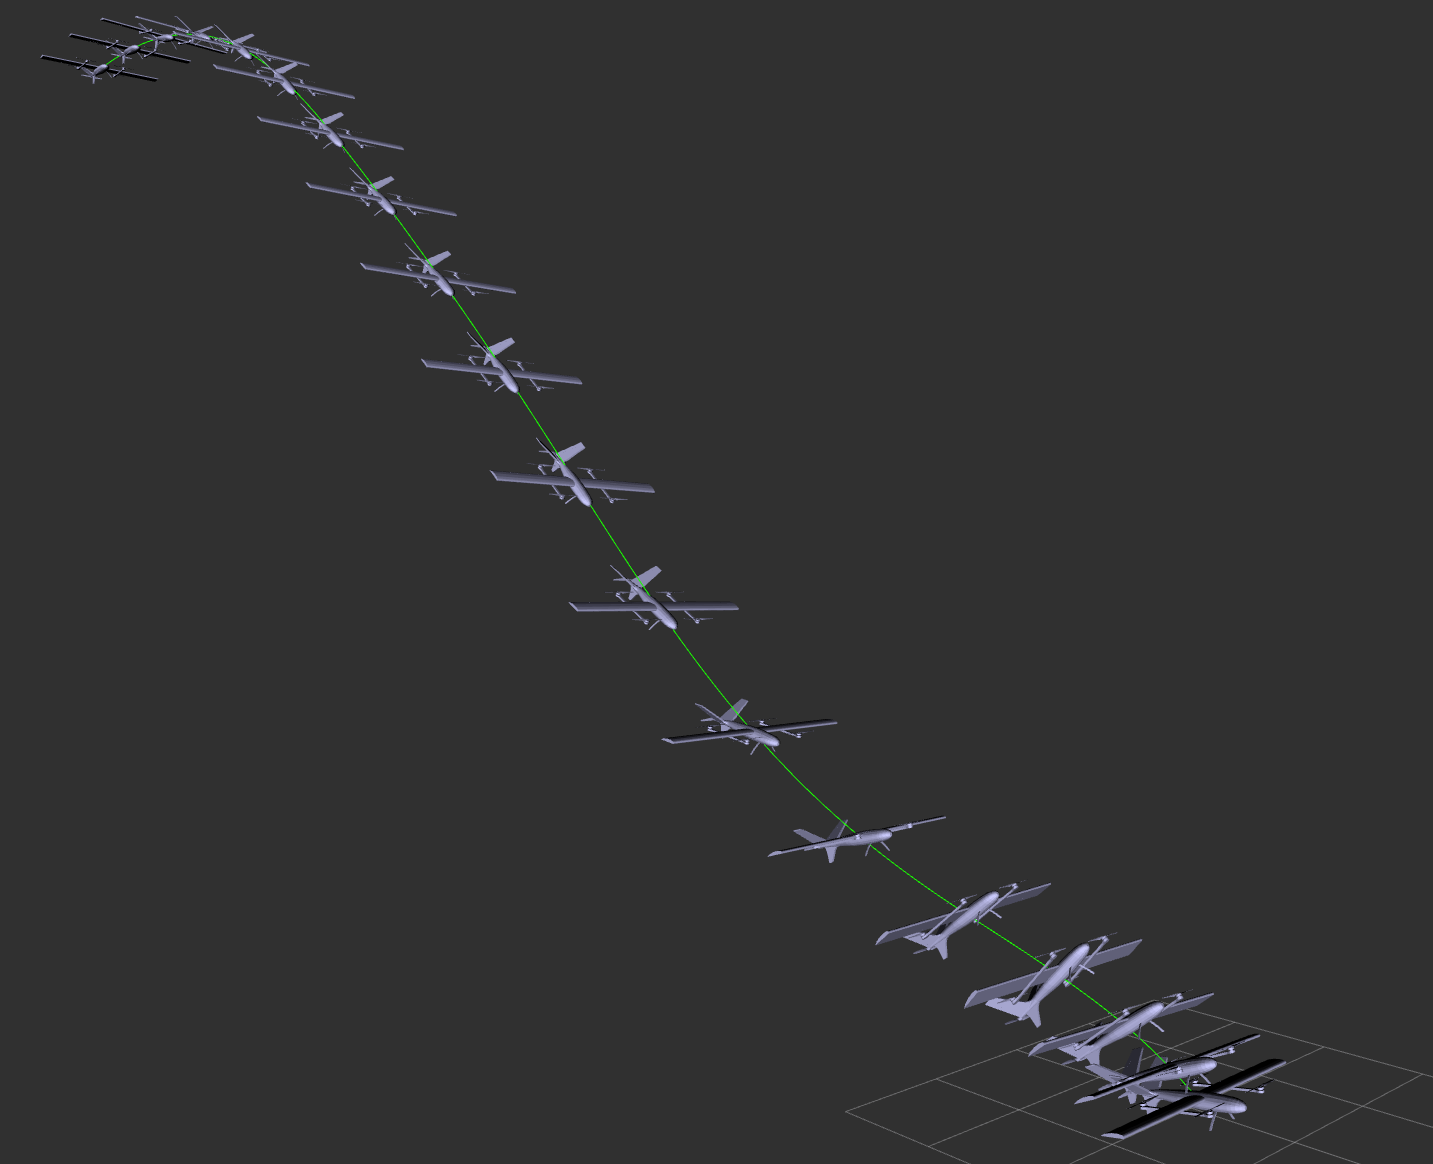
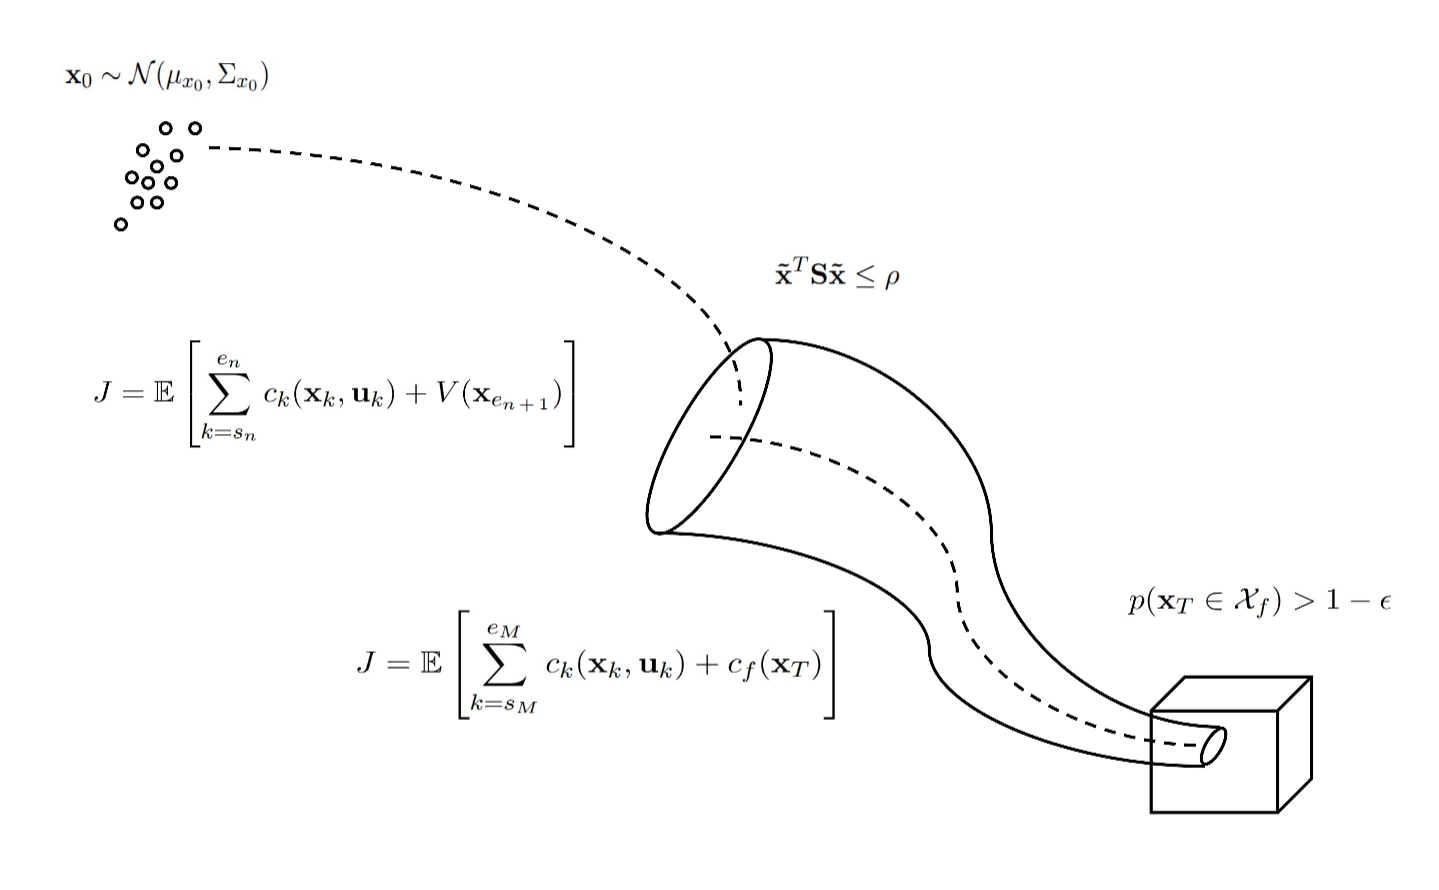
I am currently a Ph.D. candidate in the Agile and Intelligent Robotics Lab at Johns Hopkins University where I am advised by Dr. Joseph Moore. My research focuses on developing novel stochastic trajectory optimization and control algorithms for agile autonomous flight in unsteady flows, with a particular focus on safe autonomous shipboard landing in turbulent wind and rough sea conditions. This work leverages a variety of techniques including GPU-accelerated computational physics, reduced order modeling, and optimal control/reinforcement learning.
Prior to my Ph.D., I worked as a Robotics Software Engineer at Anduril Industries on counter unmanned air systems (cUAS) and aerial autonomy for robots operating in contested, GNSS-denied environments. My B.S.E is in Computer Science and Engineering from the University of Michigan, Ann Arbor. I am also an adept systems programmer by training, and I enjoy designing reliable, high-performance, high-quality software in C++ and Rust.
Feel feel to contact me for collaborations, opportunities, or just to chat.
Selected publications
3 Open-source projects
Simple Dynamical Systems
2026 - present
C++20 Concepts Library for stochastic optimal control with first-class CUDA support. Designed to be simple, fast, and extensible.
- C++
- CUDA
Geometric Quadrotor Control and EKF
2023
On-manifold quadcopter controller and Invariant EKF
- C++
- Manif
- Eigen
Position-Based Visual Servoing
2022
PBVS System for a 9 DOF Robot Arm and Torso. Supports fiducial marker based and ICP based end effector pose estimation.
- Python
- PyBullet
- OpenCV
- PyTorch
Differential Drive Model Predictive Control
2022
Tracking-Error Linearized MPC for a Differential Steering Robot with a QP MPC formulation.
- Python